* denotes equal contribution.
2026
-
Arxiv 2026
ChairNav: Cross-Embodiment Pre-training and Personalization for Long-Horizon Wheelchair Navigation
arXiv preprint arXiv:2610.24012, 2026
-
 Arxiv 2026
Monocular 3D Occupancy Perception for Robots on Sidewalks via Hybrid 2D-3D Learning
Yukai Ma, Joe Lin , Liu Liu ,
Honglin He, Lulu Ricketts, Brad Squicciarini, and
Bolei Zhou arXiv preprint arXiv:2606.19122, 2026
-
 Arxiv 2026
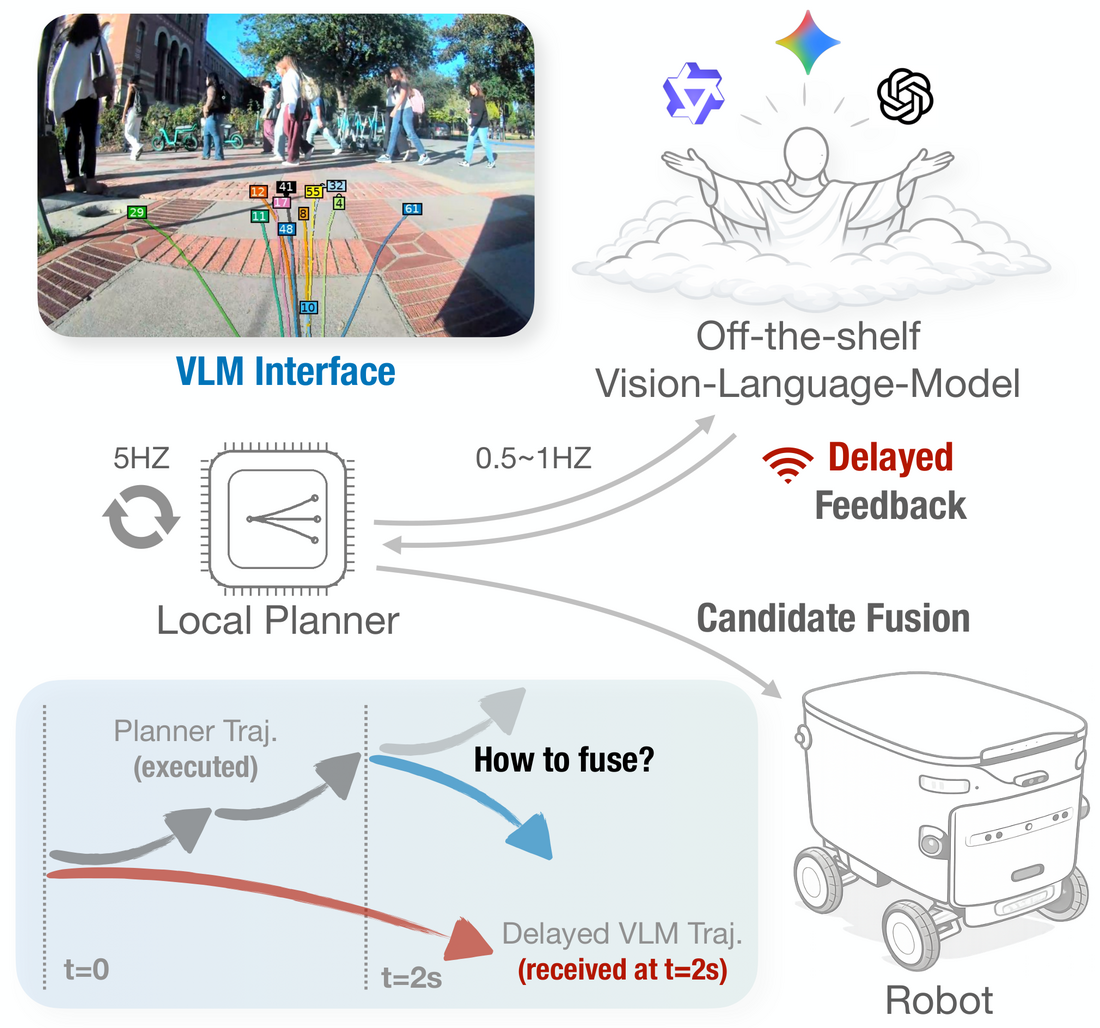
Slow Brain, Fast Planner: Latency-Resilient VLM-Augmented Urban Navigation
arXiv preprint arXiv:2606.20458, 2026
-
CoRL 2026
From Imitation to Alignment: Human-Preference Flow Policies for Long-Horizon Sidewalk Navigation
In Conference on Robot Learning, 2026
-
 CoRL 2026 Spotlight
SidewalkBench: Benchmarking Visual Navigation on Urban Sidewalks
In Conference on Robot Learning (Spotlight), 2026
-
 CoRL 2026
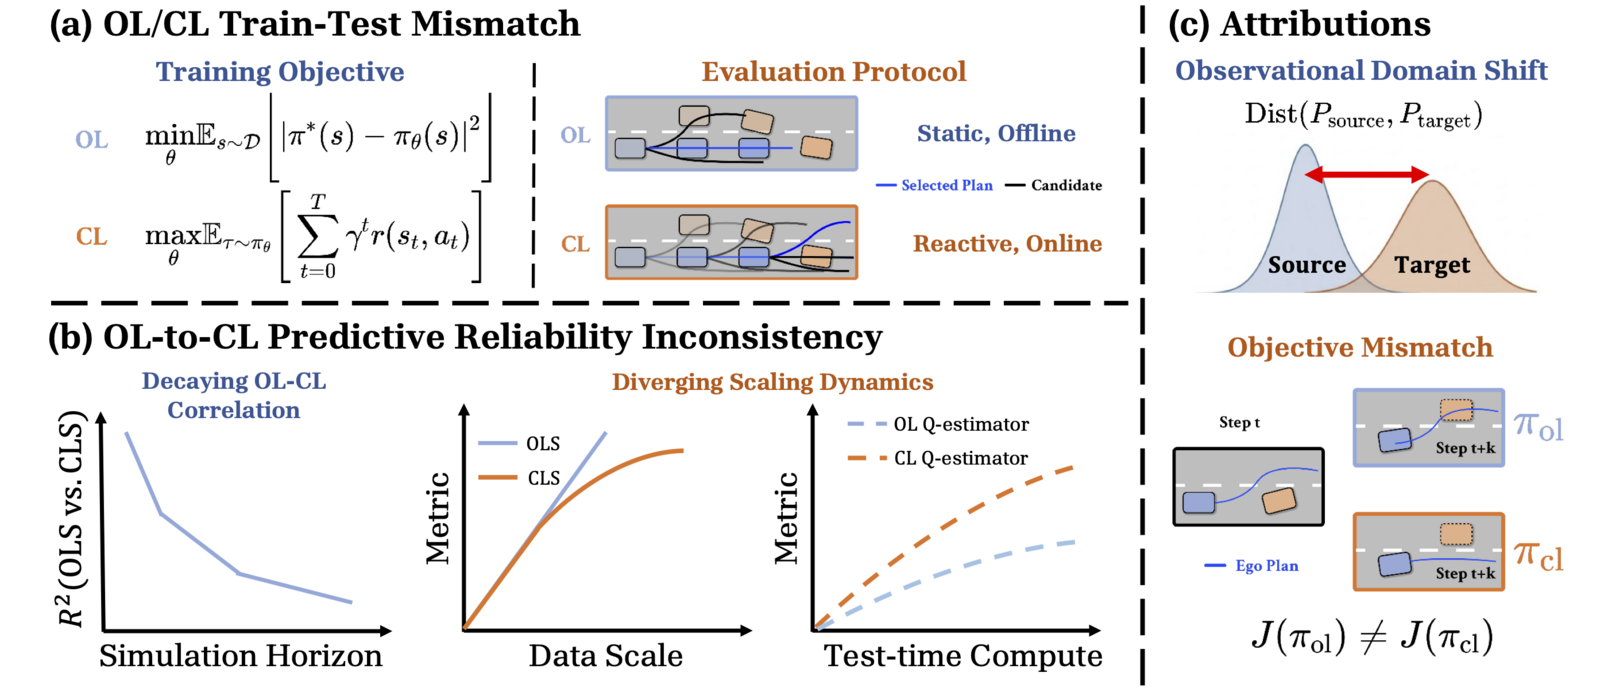
BridgeSim: Unveiling the OL-CL Gap in End-to-End Autonomous Driving
Seth Z. Zhao , Luobin Wang, Hongwei Ruan, Yuxin Bao, Yilan Chen, Ziyang Leng, Abhijit Ravichandran , Honglin He , Zewei Zhou, Xu Han, and 6 more authors
In Conference on Robot Learning, 2026
-
 ICRA 2026
Learning Sidewalk Autopilot from Multi-Scale Imitation with Corrective Behavior Expansion
In IEEE International Conference on Robotics and Automation, 2026
-
 CVPR 2026
AURA: Multi-modal Shared Autonomy for Urban Navigation
In IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2026
-
ICLR 2026
From seeing to experiencing: Scaling navigation foundation models with reinforcement learning
In International Conference on Learning Representations, 2026
-
ICLR 2026
UrbanVerse: Scaling Urban Simulation by Watching City-Tour Videos
In International Conference on Learning Representations, 2026
2025
-
 Arxiv 2025
Dreamland: Controllable World Creation with Simulator and Generative Models
arXiv preprint arXiv:2506.08006, 2025
-
CVPR 2025 Highlight
Towards Autonomous Micromobility through Scalable Urban Simulation
In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (Highlight), 2025
-
 ICLR 2025 Spotlight
2024
-
 CVPRW 2024
-
 IEEE T-ITS
Few-Shot Testing of Autonomous Vehicles with Scenario Similarity Learning
IEEE Transactions on Intelligent Transportation Systems, 2024
-
IEEE IV-S Few-shot scenario testing for autonomous vehicles based on neighborhood coverage and similarity
arXiv preprint arXiv:2402.01795, 2024
2023
-
 ICCV 2023
Orthoplanes: A novel representation for better 3d-awareness of gans
Honglin He*, Zhuoqian Yang
* , Shikai Li, Bo Dai, and
Wayne Wu In Proceedings of the IEEE/CVF International Conference on Computer Vision, 2023
-
 ICCV 2023
DNA-Rendering: A Diverse Neural Actor Repository for High-Fidelity Human-centric Rendering
Wei Cheng, Ruixiang Chen, Wanqi Yin, Siming Fan, Keyu Chen , Honglin He, Huiwen Luo, Zhongang Cai , Jingbo Wang, Yang Gao, and 1 more author
In Proceedings of the IEEE/CVF International Conference on Computer Vision, 2023
-
 IEEE TITS 2023
Adaptive safety evaluation for connected and automated vehicles with sparse control variates
IEEE Transactions on Intelligent Transportation Systems, 2023
2022
-
ITSC 2022 Adaptive testing for connected and automated vehicles with sparse control variates in overtaking scenarios
In IEEE International Conference on Intelligent Transportation Systems, 2022


